QGyroscopeReading Class
QGyroscopeReading クラスは、ジャイロセンサーからの1回の読み取り値を表します。詳細...
| ヘッダー: | #include <QGyroscopeReading> |
| CMake: | find_package(Qt6 REQUIRED COMPONENTS Sensors) target_link_libraries(mytarget PRIVATE Qt6::Sensors) |
| qmake: | QT += sensors |
| 継承元: | QSensorReading |
プロパティ
公開関数
| void | setX(qreal x) |
| void | setY(qreal y) |
| void | setZ(qreal z) |
| qreal | x() const |
| qreal | y() const |
| qreal | z() const |
詳細な説明
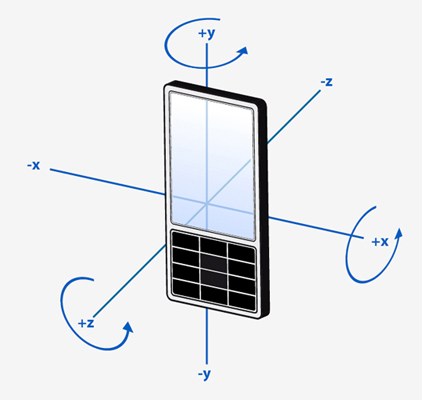
QGyroscopeReadingの単位
この読み取り値には、x軸、y軸、z軸周りのデバイスの動きを表す3つの値が含まれており、単位は度/秒です。QRotationReading とは異なり、これらの値は固定された回転ではなく、現在の角速度を表します。測定単位は度/秒です。
プロパティのドキュメント
[read-only] x : qreal
このプロパティは、x軸周りの角速度を保持します。
単位は度/秒です。
アクセス関数:
| qreal | x() const |
QGyroscopeReading Unitsも参照してください 。
[read-only] y : qreal
このプロパティは、y軸周りの角速度を保持します。
単位は度/秒です。
アクセス関数:
| qreal | y() const |
QGyroscopeReading Unitsも参照してください 。
[read-only] z : qreal
このプロパティは、z軸周りの角速度を保持します。
単位は度/秒です。
アクセス関数:
| qreal | z() const |
「QGyroscopeReading Units」も参照してください 。
© 2026 The Qt Company Ltd. Documentation contributions included herein are the copyrights of their respective owners. The documentation provided herein is licensed under the terms of the GNU Free Documentation License version 1.3 as published by the Free Software Foundation. Qt and respective logos are trademarks of The Qt Company Ltd. in Finland and/or other countries worldwide. All other trademarks are property of their respective owners.
