
QGyroscopeReading Class
QGyroscopeReading 클래스는 자이로스코프 센서에서 얻은 한 번의 측정값을 나타냅니다. 더 보기...
| 헤더: | #include <QGyroscopeReading> |
| CMake: | find_package(Qt6 REQUIRED COMPONENTS Sensors) target_link_libraries(mytarget PRIVATE Qt6::Sensors) |
| qmake: | QT += sensors |
| 상속: | QSensorReading |
속성
공개 함수
| void | setX(qreal x) |
| void | setY(qreal y) |
| void | setZ(qreal z) |
| qreal | x() const |
| qreal | y() const |
| qreal | z() const |
상세 설명
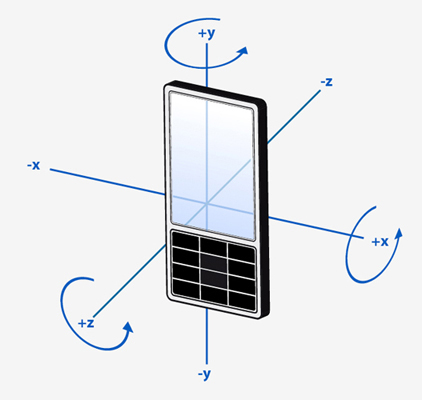
QGyroscopeReading Units
이 판독값에는 x, y, z 축을 중심으로 한 기기의 움직임을 정의하는 3개의 값이 포함되어 있으며, 단위는 초당 도(deg/s)입니다. ` QRotationReading`와 달리, 이 값들은 고정된 회전 각도가 아닌 현재 각속도를 나타냅니다. 측정 단위는 초당 도(deg/s)입니다.
속성 설명
[read-only] x : qreal
이 속성은 x축을 중심으로 한 각속도를 나타냅니다.
단위는 초당 도(°/s)입니다.
액세스 함수:
| qreal | x() const |
QGyroscopeReading Units도 참조하십시오 .
[read-only] y : qreal
이 속성은 y축을 중심으로 한 각속도를 나타냅니다.
단위는 초당 도입니다.
액세스 함수:
| qreal | y() const |
QGyroscopeReading Units도 참조하십시오 .
[read-only] z : qreal
이 속성은 z축을 중심으로 한 각속도를 나타냅니다.
단위는 초당 도(°/s)입니다.
액세스 함수:
| qreal | z() const |
QGyroscopeReading Units도 참조하십시오 .
© 2026 The Qt Company Ltd. Documentation contributions included herein are the copyrights of their respective owners. The documentation provided herein is licensed under the terms of the GNU Free Documentation License version 1.3 as published by the Free Software Foundation. Qt and respective logos are trademarks of The Qt Company Ltd. in Finland and/or other countries worldwide. All other trademarks are property of their respective owners.
